AVAILABLEROBOTIC WORKSTATION PLATFORM

Meet SAM — Sliding Arm Machine

A multi-degree-of-freedom robotic workstation architecture for applications needing dexterity, workspace flexibility, and integrated motion control.

DRAG TO ROTATE SCROLL TO EXPLODEEXPLODE 0%
LINEAR AXES · 2
Two linear axes position each arm along the workstation for flexible access to the working area.
01Introducing SAM

A platform for building robotic applications.

SAM combines linear positioning with multi-axis rotational motion in a sliding-arm architecture, giving flexible access to a working area.

It supports application-specific tools, end effectors, and workflows — a platform for building robotic applications, not just a standalone manipulator.
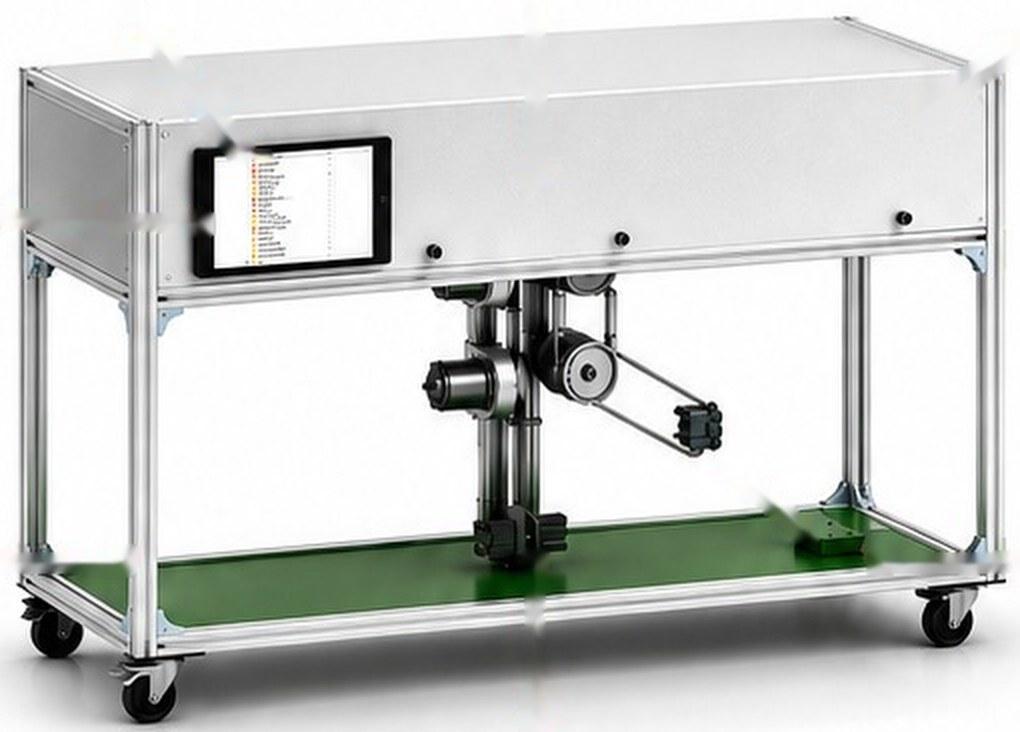
SAM product render: aluminium-frame workstation on castors with an enclosed top housing, a 10-inch touchscreen, an overhead sliding arm and a green work surface.
SAM · PRODUCT RENDERSTANDARD FOOTPRINT · 4 FT × 2 FT × 2.5 FT
12
DEGREES OF FREEDOM
2
LINEAR AXES
10
ROTATIONAL DOF
×2
DUAL-ARM
02Platform architecture
2 + 10

12 degrees of freedom

2 linear axes plus 10 rotational across a dual-arm configuration.

Dual-arm manipulation

Two arms for coordinated tasks within one workspace.

Integrated motion control

Dreambot-developed electronics, drivers, and software.

Configurable workspace

Application-oriented layout, tooling, and fixtures.

Software integration

Control, visualization, application development, and simulation.

03Technical overview

Datasheet

SAM · FEATURE SPECIFICATION
PLATFORMSAM — Sliding Arm Machine
ARCHITECTURESliding-arm workstation · dual-arm or single-arm models
DEGREES OF FREEDOM12
LINEAR AXES2
ROTATIONAL DOF10
ARM DOF4–5 per arm
REACH3 ft · enhanced-reach options available
PAYLOAD2 kg
ACCURACY0.5 mm initial accuracy (cost-effective variant)
FOOTPRINT4 ft × 2 ft × 2.5 ft (customizable)
CONTROL & INTERFACE10" touch display with soft pendant · hardware teach pendant option · Linux-based controller UI
PROGRAMMINGG-code style scripting · batch-file programming and command language
COMPUTERaspberry Pi or NVIDIA Orin Nano GPU controllers
CONNECTIVITYEthernet (10/100 Mbps) · USB 2.0 · Wi-Fi · SD card
SAFETYFully enclosed design with auto-safety mechanisms
FRAMEAluminum — lightweight, durable and modular
VISIONOnboard camera system · machine-vision libraries
SOFTWARELinux-based open-source platform · command-based interface and API
INTEGRATIONIntegrated conveyor belt interface · multi-station integration
ACTUATIONApplication-specific, integrated motion-control architecture
END EFFECTORSApplication-specific
AVAILABILITYFully assembled or DIY kit
INTENDED USERSOEMs, system integrators, developers, manufacturers, students, researchers

Figures are for the standard configuration; footprint and reach can be customized per application. Speed specifications will be published against a defined hardware revision and tested configuration.

04Where SAM can be applied
Robotic cookingPick-and-place & material handlingWorkstation assemblyEducation & researchApplication prototypingSpecialized automation cells
05 · DESIGNED FOR PLATFORM DEVELOPMENT

Selected per task. Integrated as one.

Gripper, sensing, fixtures, peripherals, motion profiles, and workflow software are selected per task — reducing the effort from concept to integrated application.

GRIPPER
SENSING
FIXTURES
PERIPHERALS
MOTION
WORKFLOW
> BUILD_ON_SAM

Build your next robotic application on SAM.

Discuss payload, workspace, tooling, integration, and requirements with our engineering team.
Request a Technical Discussion